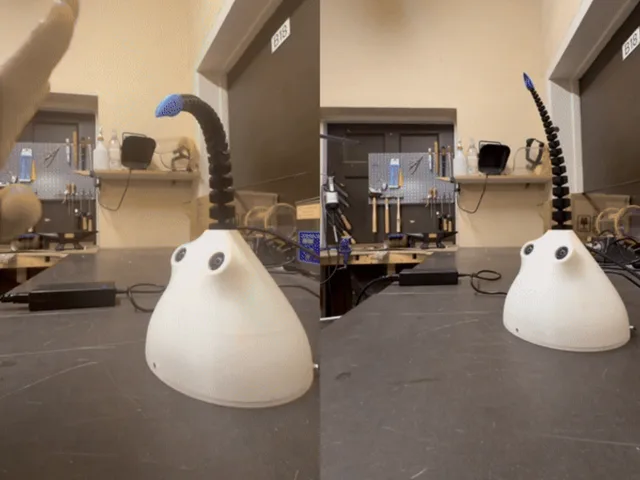
Building Shoggoth Mini — Part 2: Shoggoth Mirror
2026
A perception and behaviour layer on top of the build: face tracking, an affect estimate, a state machine defined in spreadsheets, and a motion vocabulary to play it back.
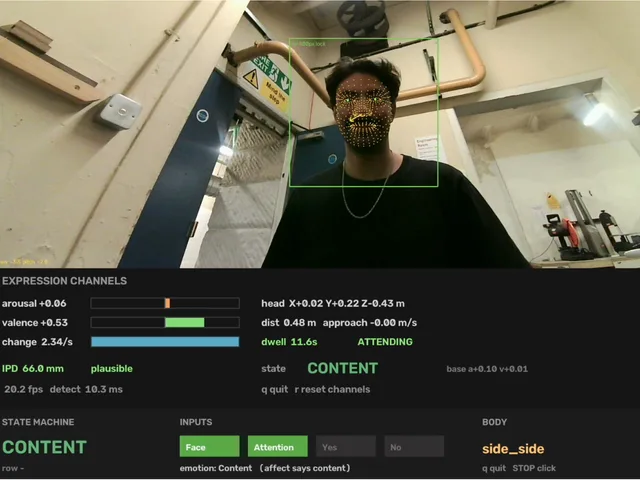
2026
A perception and behaviour layer on top of the build: face tracking, an affect estimate, a state machine defined in spreadsheets, and a motion vocabulary to play it back.
2026
Assembling and bringing up a soft robotic tentacle: a redesigned dome, stereo calibration, and a characterisation of the servos that corrected several wrong assumptions — including one that had been destroying tendons.